VPL-A0752E-PJ12AA
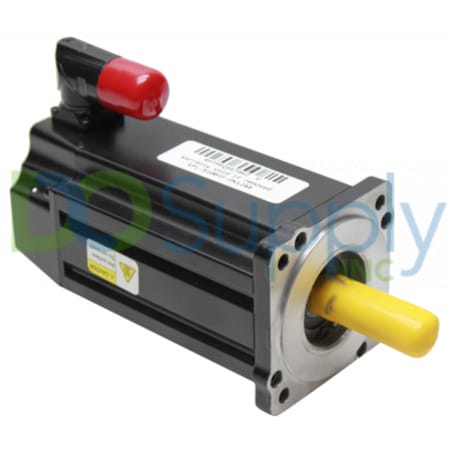
This servo motor is designed with a 75 mm frame size and utilizes two magnet stacks for enhanced performance. It has an 18-bit absolute multi-turn digital encoder that employs the Hiperface DSL protoc
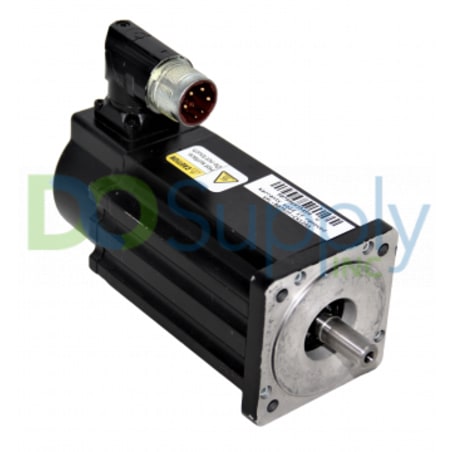
Allen Bradley's Kinetix VPL servo motors feature low inertia and are suitable for high-performance motion control applications. The VPL servo motors offer real-time motor performance information to the control system via single-turn or multi-turn absolute encoders. They are available in a 200V voltage class or a 400V voltage class, and different servo motors can operate at different rated speeds. Some VPL servo motors include 24V DC holding brakes. The VPL servo motors are optimized to match the ratings of Kinetix 5500 and 5700 drives.
Browse available units in our catalog of VPL Servo Motors.
This servo motor is designed with a 75 mm frame size and utilizes two magnet stacks for enhanced performance. It has an 18-bit absolute multi-turn digital encoder that employs the Hiperface DSL protoc
This low-inertia motor supports a rating of 200 volts and can achieve speeds up to 4500 RPM. It features three magnet stacks and utilizes an 18-bit absolute multi-turn encoder with the Hiperface DSL p
The VPL-A1001M-CJ12AS Low-inertia Servo Motor has 1 Magnet Stack, a Shaft Key Shaft , and a 18-bit absolute single-turn digital encoder (Hiperface DSL protocol) Feedback.
Designed with six magnet stacks, the VPL-B1306F-PK12AA provides enhanced torque capabilities. This motor uses an 18-bit absolute multi-turn digital encoder with Hiperface DSL protocol for feedback acc
Offering two magnet stacks, this low-inertia servo motor provides efficient operation with a maximum rated speed of 2500 RPM. It features an 18-bit absolute multi-turn digital encoder operating under
The VPL-B1652C-CK12AA Low-inertia Servo Motor has 2 Magnet Stacks, a Smooth Shaft , and a 18-bit absolute single-turn digital encoder (Hiperface DSL protocol) Feedback.
This servo motor model features an 18-bit absolute multi-turn digital encoder utilizing the Hiperface DSL protocol for accurate feedback. A smooth shaft and a right-angle SpeedTec DIN connector are in
This servo motor, designed for precision control, features three magnet stacks and uses an 18-bit absolute single-turn digital encoder based on the Hiperface DSL protocol. It has a smooth shaft and a
This servo motor has two magnet stacks and utilizes an 18-bit absolute multi-turn digital encoder, which operates with the Hiperface DSL protocol for reliable feedback. Additionally, its smooth shaft
With a single magnet stack, this servo motor features an 18-bit absolute single-turn digital encoder based on the Hiperface DSL protocol for accurate feedback. The smooth shaft design contributes to e